Adaptive Robotics Lab

The Adaptive Robotics Lab at Colorado State University designs and builds small robots that adapt to new tasks and environments by changing their shape, stiffness, structure, or way of moving. We combine soft materials, reconfigurable mechanisms, and bio-inspired design with modeling and control, with applications in search and rescue, infrastructure inspection, space exploration, and environmental monitoring. The lab is directed by Prof. Jianguo Zhao and is located at the Powerhouse Energy Campus in Fort Collins, Colorado.

Research areas
News
Nov 11, 2026
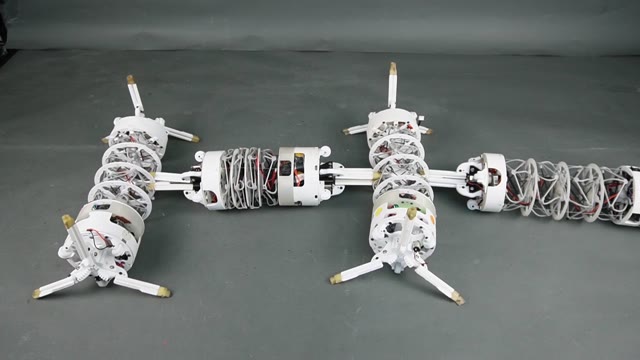
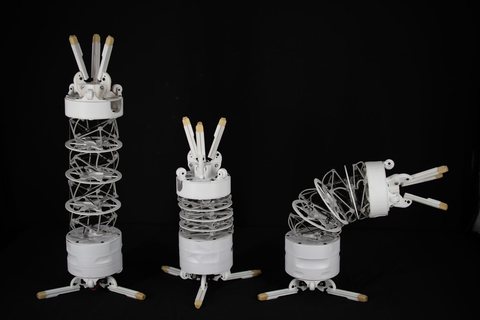
Our paper on TeCoBot, soft modular robots that link up into chains, loops, and branches to work as a team, is published in Nature Machine Intelligence. Congratulations, Mahmud, Sydney, Sudheera, Andrew, and Josh!
Oct 27, 2026
Andrew Stefka successfully defended his M.S. thesis, “Driving, Flying, Swimming, and Perching Robot.”
Oct 26, 2026
Josh Chrisler successfully defended his M.S. thesis, “Transformable Wheel-legged Robots.”
Aug 12, 2026
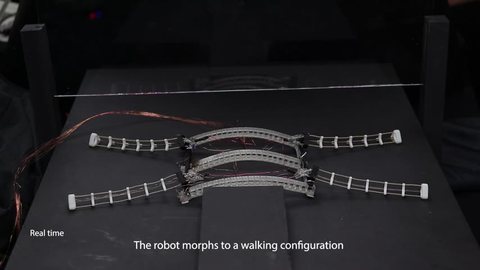
Eli’s paper on a stiffness-programmable origami robot, 3D-printed fingers that grasp and walk in different ways under the same tendon actuation, is published open access in Advanced Robotics Research.

Selected publications

  1. Nat. Mach. Intell.
    saikot2026tecobot.jpg
    Tensegrity Continuum Robots Enable Task-Adaptive Morphologies for Cooperative Behaviours
    Mahmud Hasan Saikot, Sydney Spiegel, Sudheera Akalanka Kariyawasam, and 3 more authors
    Nature Machine Intelligence, 2026
  2. Nat. Commun.
    sun2023embedded.jpg
    Embedded Shape Morphing for Morphologically Adaptive Robots
    Jiefeng Sun, Elisha Lerner, Brandon Tighe, and 2 more authors
    Nature Communications, 2023
  3. T-Mech
    spiegel2023tensegrity.jpg
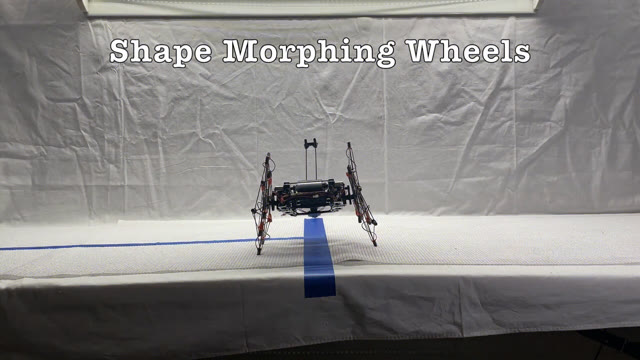
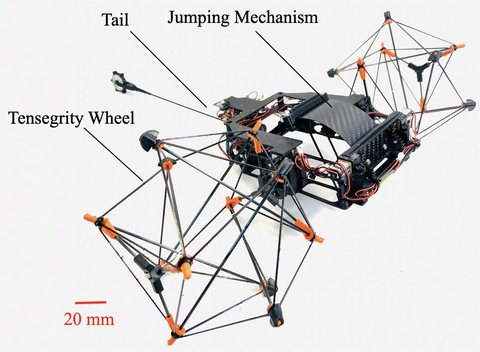
    A Shape-Changing Wheeling and Jumping Robot Using Tensegrity Wheels and Bistable Mechanism
    Sydney Spiegel, Jiefeng Sun, and Jianguo Zhao
    IEEE/ASME Transactions on Mechatronics, 2023
  4. T-Mech
    hsiao2022gripper.jpg
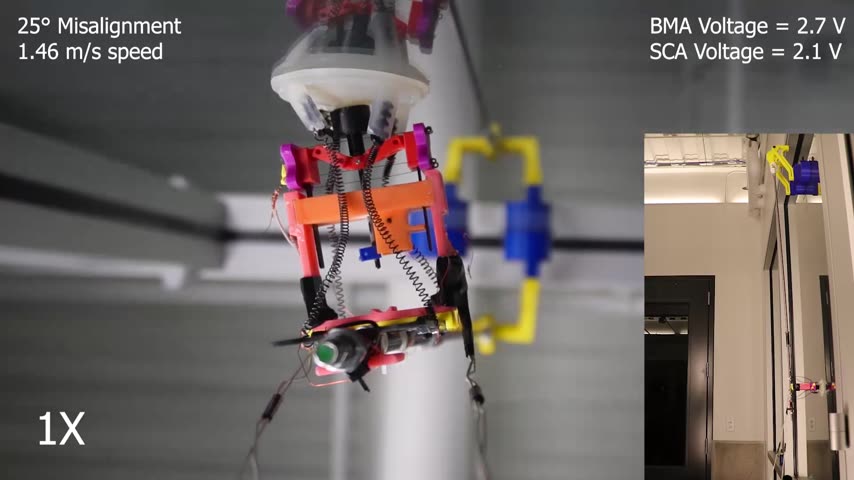
    A Mechanically Intelligent and Passive Gripper for Aerial Perching and Grasping
    Billy Hsiao, Jiefeng Sun, Haijie Zhang, and 1 more author
    IEEE/ASME Transactions on Mechatronics, 2022
  5. T-RO
    sun2022cosserat.jpg
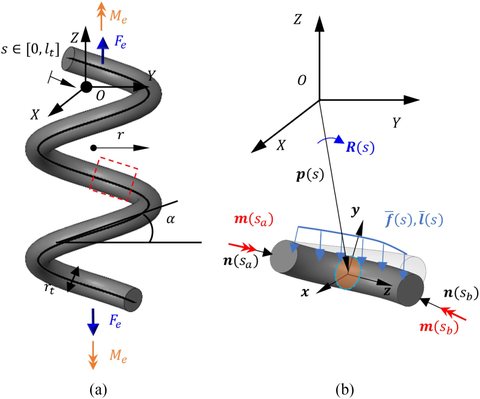
    Physics-based Modeling of Twisted-and-Coiled Actuators Using Cosserat Rod Theory
    Jiefeng Sun and Jianguo Zhao
    IEEE Transactions on Robotics, 2022

Join us

We are always looking for motivated graduate and undergraduate students interested in robotics, controls, mechanical design, mechatronics, and embedded systems. Please email Prof. Zhao with your CV, or search "Adaptive Robotics Laboratory" at jobs.colostate.edu. We also welcome collaborations with industry partners.