News
Nov 11, 2026
Our paper on TeCoBot, soft modular robots that link up into chains, loops, and branches to work as a team, is published in Nature Machine Intelligence. Congratulations, Mahmud, Sydney, Sudheera, Andrew, and Josh! 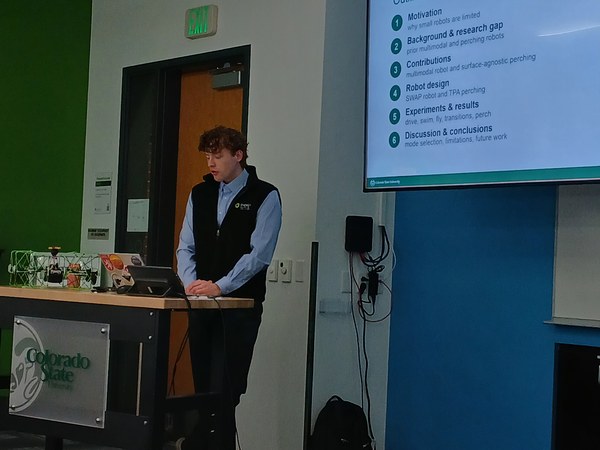
Oct 27, 2026
Andrew Stefka successfully defended his M.S. thesis, “Driving, Flying, Swimming, and Perching Robot.” 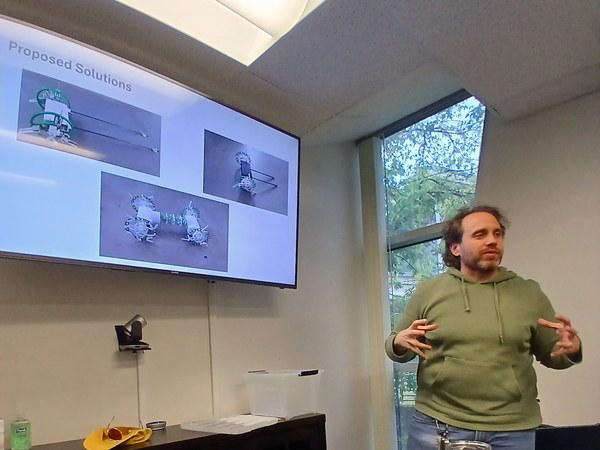
Oct 26, 2026
Josh Chrisler successfully defended his M.S. thesis, “Transformable Wheel-legged Robots.” 
Aug 12, 2026
Eli’s paper on a stiffness-programmable origami robot, 3D-printed fingers that grasp and walk in different ways under the same tendon actuation, is published open access in Advanced Robotics Research. 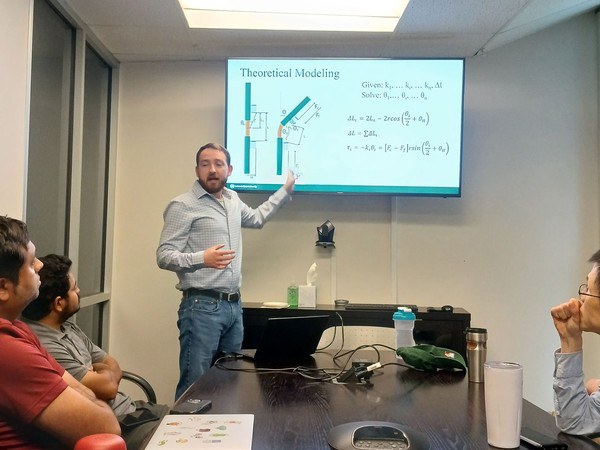
Aug 10, 2026
Congratulations to Dr. Elisha Lerner on completing his Ph.D. Dissertation: “Enabling Physically Intelligent Robots through Stiffness Tuning.” 
Dec 15, 2025
Congratulations to Dr. Zhe Chen on completing his Ph.D. Dissertation: “Modular Reconfigurable Robots Capable of Programmable Shapes and Motions.” 
Sep 01, 2025
Our lab received an NSF grant (MORPHOSIS), in collaboration with Prof. Jiefeng Sun (Arizona State University), on modeling and control of high-dimensional shape-morphing structures. 
Dec 16, 2024
Clint successfully defended his M.S. thesis, “Shape Morphing Robotic Fish.” 
Sep 15, 2024
Our lab was awarded an NSF grant, with Prof. Cheng (Penn State) and Prof. Lauder (Harvard), to study modular robotic swimmers that can artificially evolve for better mobility in challenging hydrodynamic environments. 
Aug 15, 2024
Bryce successfully defended his M.S. thesis, “Bistable Prestressed Spring Steel Grippers for Aerial Perching and Grasping.” 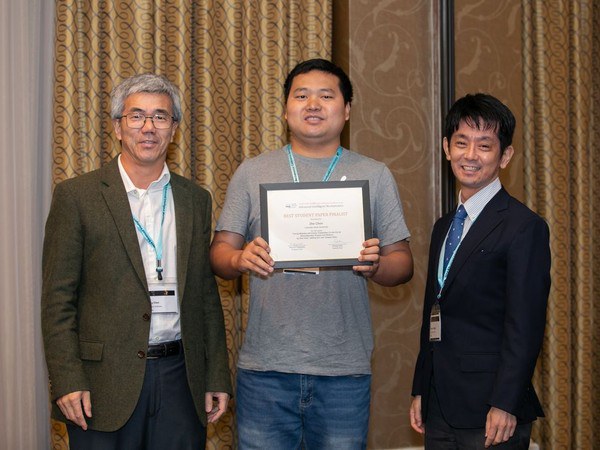
Jan 15, 2024
Jiefeng started as a tenure-track Assistant Professor at Arizona State University. Congratulations! 
Sep 15, 2023
We published a paper in Nature Communications describing an embedded shape-morphing method for morphologically adaptive robots. 
Aug 20, 2023
Our lab was awarded an NSF grant, with Prof. Cheng (Penn State), to enable flying robots to perch on dynamic surfaces. 
Aug 10, 2023
We published a paper in IEEE/ASME Transactions on Mechatronics on tensegrity wheels that let a mobile robot actively expand or collapse its wheels. 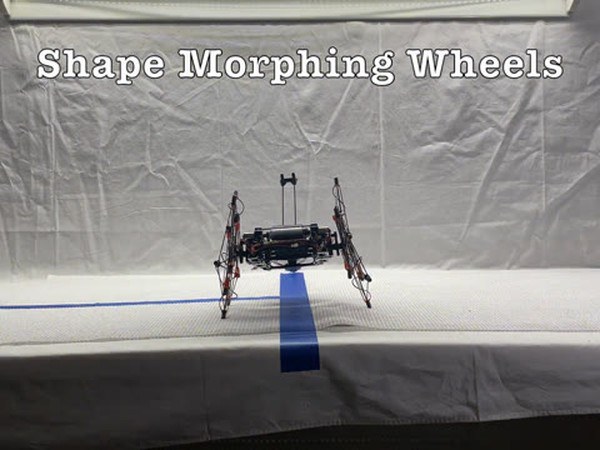
Apr 15, 2023
Sydney won the top prize and a $2K award at CSU Demo Day for an all-terrain robot based on tensegrity structures. 
Mar 15, 2023
Ajai successfully defended his M.S. thesis, “Modeling, Simulation, and Control of Soft Robots Using Koopman Operator Theory.” 
Sep 15, 2022
We published a paper in Materials Horizons, with Dr. Kota (NCSU), showing soft robotic manipulation of biofluid droplets. 
Aug 15, 2022
We published a paper in IEEE/ASME Transactions on Mechatronics on a reconfigurable robot that can walk, crawl, and grasp using origami-inspired modules. 
May 20, 2022
Jiefeng successfully defended his Ph.D. thesis, “Soft and Shape Morphing Robots Driven by Twisted-and-Coiled Actuators,” and joined Prof. Rebecca Kramer-Bottiglio’s group at Yale as a postdoc. 
May 10, 2022
Dr. Zhao began serving as an Associate Editor for IEEE Transactions on Robotics. 
Apr 15, 2022
Brandon successfully defended his M.S. thesis on free-stroke twisted-and-coiled actuators and was featured as an outstanding CSU graduate. 
Dec 15, 2021
Our lab was awarded an NSF grant, with Prof. Yin (NCSU), to study tunable elastic instabilities for multifunctional soft robots. 
Aug 20, 2021
Dr. Zhao began serving as a Technical Editor for IEEE/ASME Transactions on Mechatronics. 
May 15, 2021
Dr. Zhao was promoted to Associate Professor with tenure. 
Nov 20, 2020
We published a paper in IEEE/ASME Transactions on Mechatronics showing how mechanical intelligence, in the form of compliant bistable grippers, enables passive perching for small aerial robots. The work was featured by New Atlas. 
Nov 15, 2020
Haijie successfully defended his Ph.D. dissertation, “Biologically Inspired Perching for Aerial Robots,” becoming the lab’s first Ph.D. graduate. 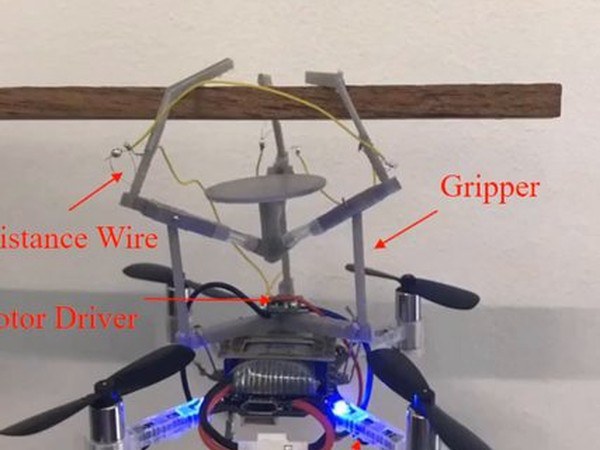
Sep 15, 2020
Our lab was granted a patent on the bistable gripper for aerial grasping and perching. 
Jul 10, 2020
We published a paper in Soft Robotics showing how twisted-and-coiled actuators with free strokes enable soft robots with programmable motions. The work was featured in CSU News. 
May 08, 2020
We published a paper in Science Advances, led by Prof. Yin (NCSU), showing how elastic instabilities can make soft robots both fast and strong. 
Mar 15, 2020
With Opterus R&D, our lab received a DARPA STTR grant to study self-reconfigurable ground robots. 
Oct 15, 2019
We published a paper in Science Advances, led by Dr. Cheng (Penn State), revealing the coupled mechanical and computational intelligence that lets flies land upside down on a ceiling. 
Aug 15, 2019
Ben Pawlowski successfully defended his M.S. thesis, “Modeling, Simulation, and Control of Soft Robots.” 
Apr 15, 2019
Our group members received several awards: Brandon Tighe won 2nd place at the Multicultural Undergraduate Research Art and Leadership Symposium (MURALS) and the junior researcher award at E-Days; Jordan Julian earned high honors at the Celebrate Undergraduate Research and Creativity Showcase (CURC) for his research on walking robots; and the NASA robotic mining team, supervised by Dr. Zhao, was selected as the 1st-place mechanical engineering senior design project. 
Feb 20, 2019
Our lab joined the annual Little Shop of Physics open house as a science partner, showing our robots to more than 8,000 visitors. 
Feb 12, 2019
Our research on reconfigurable robots, published in IEEE Robotics and Automation Letters, was featured on the IEEE Spectrum robotics blog. 
Oct 01, 2018
Jiefeng and Ben’s paper on embedded shape morphing using twisted-and-coiled actuators was a finalist for the Best Student Paper Award at IEEE/RSJ IROS 2018. 
Aug 15, 2018
Our lab received an NSF grant, with Dr. Bo Cheng (Penn State), to study vision-guided perching for small flying robots. 
May 15, 2018
Dr. Zhao received the NSF Research Initiation Award (CRII) to study embedded and continuous shape morphing using twisted-and-coiled actuators. 
Jan 15, 2018
Anthony DeMario successfully defended his M.S. thesis, “3D Printable Walking Robot with Soft Joints and Links.” 
Dec 15, 2017
Ali Abbas successfully defended his M.S. thesis, “Modeling of Twisted and Coiled Artificial Muscle for Actuation and Self-Sensing,” becoming the lab’s first M.S. graduate. 
Aug 15, 2015
The Adaptive Robotics Laboratory was established at Colorado State University.