Research
To create adaptive robots, we leverage mechanical and biological principles, novel materials, and dynamic control to guide our design.
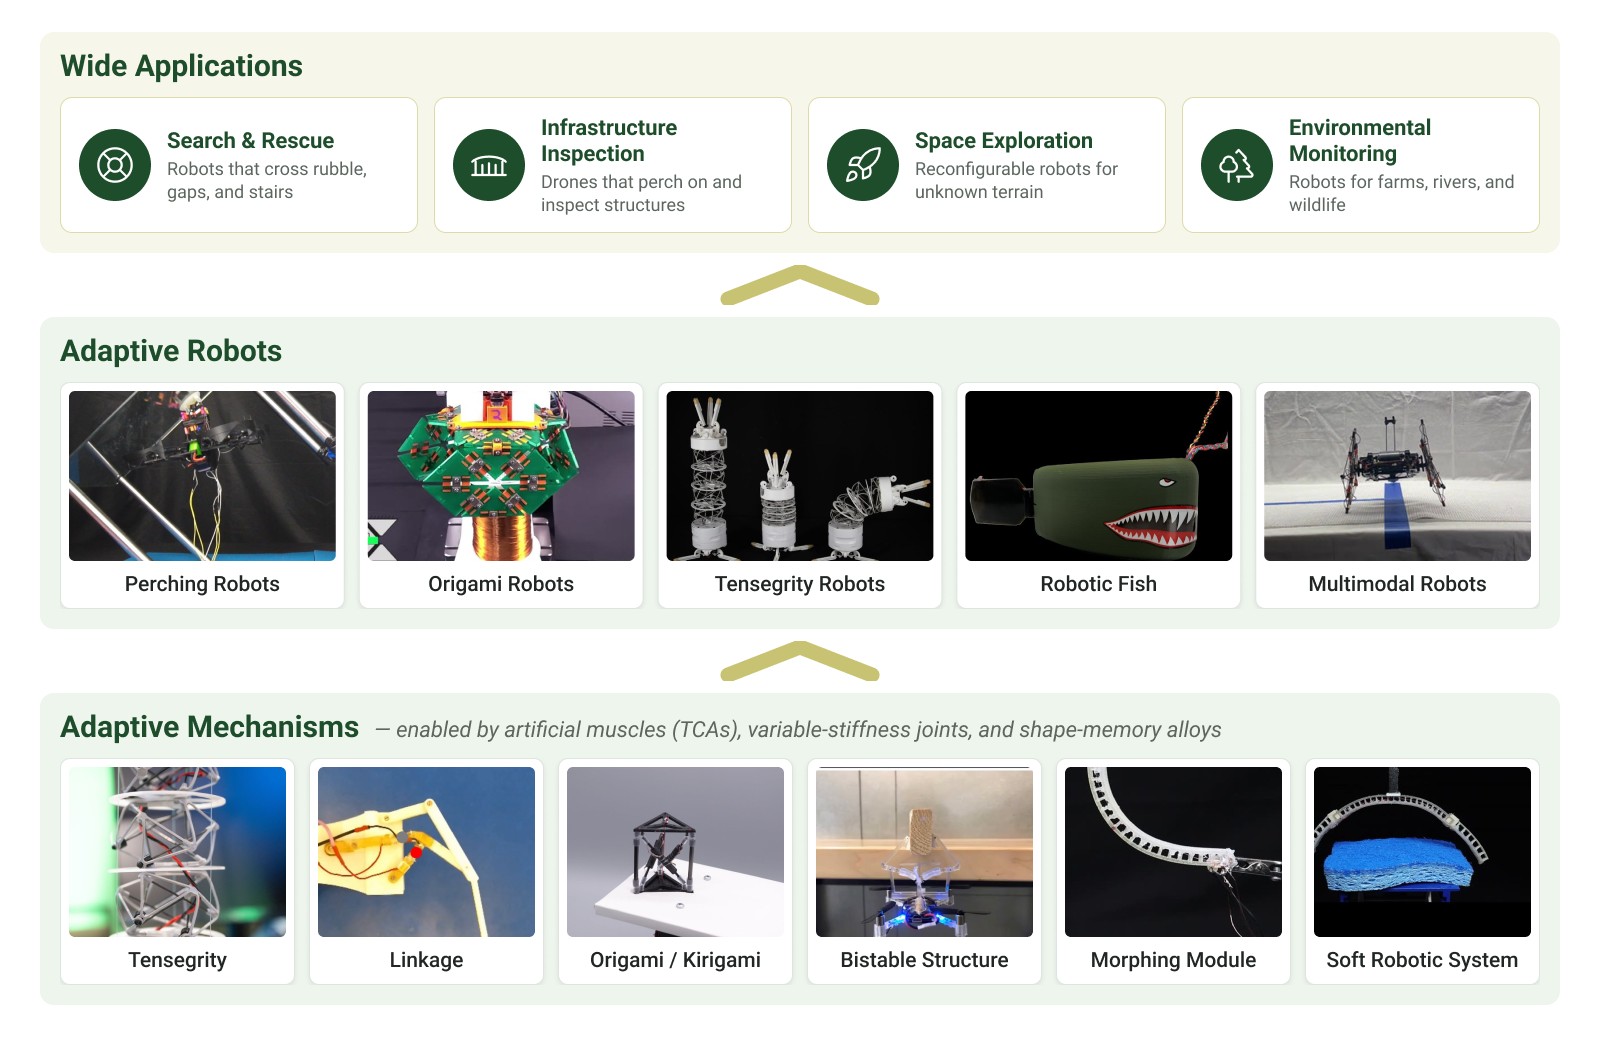
Our research spans four connected areas. Click an area to see what we study, key results, and the related robots and papers.
Research support
Our research is supported by the National Science Foundation (NSF), DARPA, the Colorado Office of Economic Development and International Trade (OEDIT), and the Center for Transformative Infrastructure Preservation and Sustainability (CTIPS).