Aerial Robots
Small flying robots that perch on branches, walls, and ceilings to save energy, and grasp objects in flight.
Small drones can only stay in the air for a few minutes because hovering uses a lot of energy. Birds and insects solve this by perching. If a drone can perch on a branch, a wall, or a ceiling, it can save or even harvest energy while it watches, measures, or inspects. We study how small aerial robots can perch reliably and how they can pick up and carry objects.
Questions we work on
- Mechanical intelligence. Can a gripper close by itself the moment it touches a target, with no sensing or power? We use bistable mechanisms that snap shut on impact and hold with no energy.
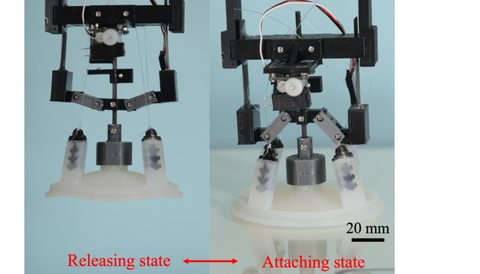
- Perching on any surface. How can one mechanism perch on both branches and flat surfaces, even when the drone arrives fast or at a large tilt?
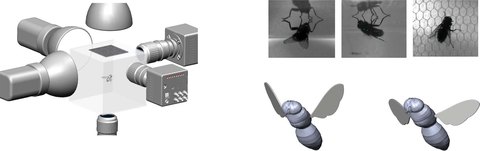
- Seeing and landing. How do flies land upside down on a ceiling, and how can a robot use vision, such as time-to-contact, to time its landing?
- Aerial grasping. How can a drone grasp and carry objects with a compliant gripper and an adaptive controller?
Key results
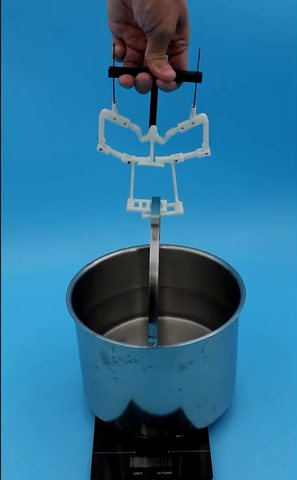
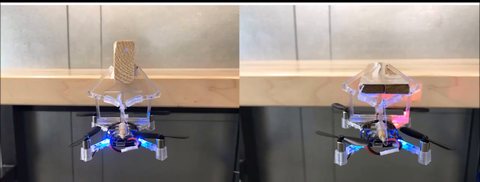
Compliant bistable grippers. A micro aerial vehicle perches passively on a pipe.
A mechanically intelligent gripper closes on the bar as the drone flies into it.
Tunable perching. Tuning the mechanism lets a drone perch on a surface tilted 25° and hit at speed (slow motion).
Bistable spring-steel grippers snap closed on contact and hold with no power.
The video at the top shows our hybrid perching mechanism landing on both a tree branch and flat surfaces.
Publications
- RA-L
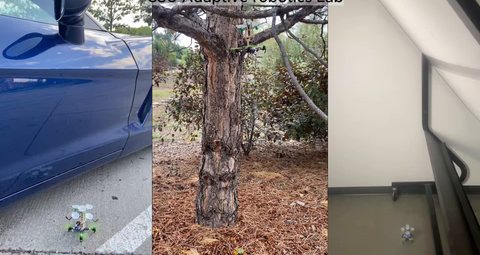 A Hybrid Perching Mechanism for Aerial Robots: Branch and Surface Perching with Large Surface Orientation MisalignmentIEEE Robotics and Automation Letters, 2026
- T-Mech
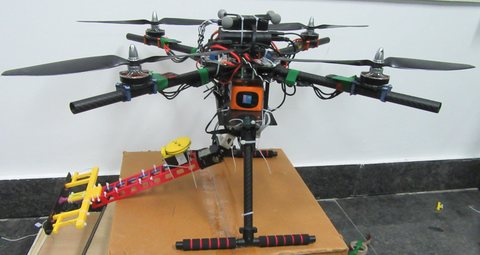 An Integrated Approach to Aerial Grasping: Combining a Bistable Gripper with Adaptive ControlIEEE/ASME Transactions on Mechatronics, 2025
- AIS
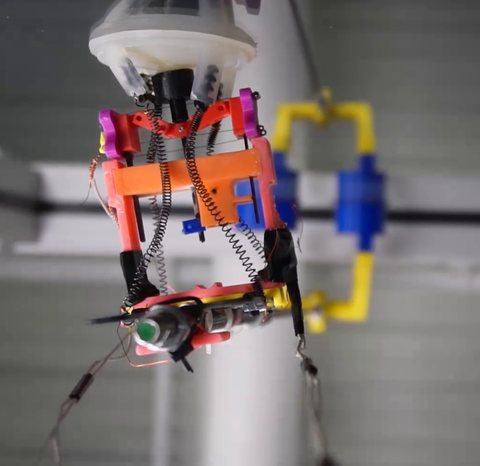 Tunable Mechanism Enables Robust Surface Perching under Different Landing Impacts and Orientation MisalignmentAdvanced Intelligent Systems, 2025
- RoboSoft
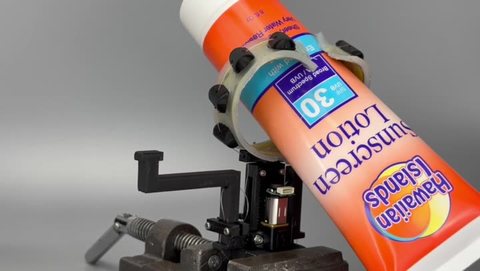 Bistable Spring Steel Grippers for Passive GraspingIn IEEE International Conference on Soft Robotics (RoboSoft), 2024
- T-Mech
 A Mechanically Intelligent and Passive Gripper for Aerial Perching and GraspingIEEE/ASME Transactions on Mechatronics, 2022
- ICRA
 A Novel Passive Mechanism for Flying Robots to Perch onto SurfacesIn IEEE International Conference on Robotics and Automation (ICRA), 2022
- T-MECH
 Compliant Bistable Grippers Enable Passive Perching for Micro Aerial VehiclesIEEE/ASME Transactions on Mechatronics, 2021
- Sci. Adv.
 Flies Land Upside Down on a Ceiling Using Rapid Visually Mediated Rotational ManeuversScience Advances, 2019
- B&B
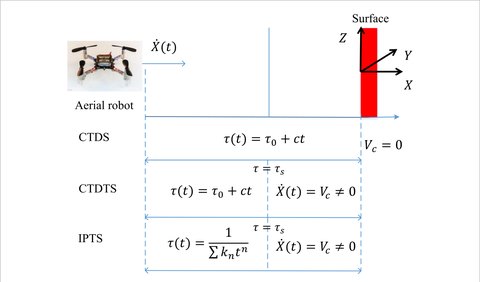 Optimal Trajectory Generation for Time-to-Contact Based Aerial Robotic PerchingBioinspiration & Biomimetics, 2019
- ICRA
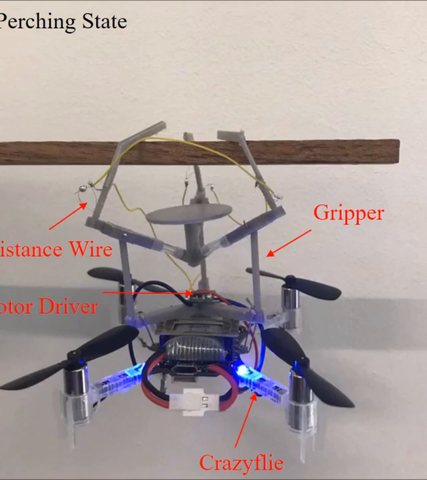 Compliant Bistable Gripper for Aerial Perching and GraspingIn IEEE International Conference on Robotics and Automation (ICRA), 2019
- B&B
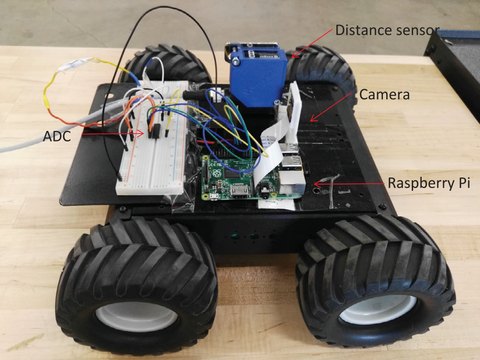 Bio-inspired Vision Based Robot Control Using Featureless Estimations of Time-to-ContactBioinspiration & Biomimetics, 2017