Publications
Selected publications in reverse chronological order. For the full list, see Dr. Zhao's Google Scholar.
2026
- T-Mech
 Co-Optimizing Physical Reconfiguration Parameters and Controllers for a Reconfigurable ManipulatorIEEE/ASME Transactions on Mechatronics, 2026
- RA-L
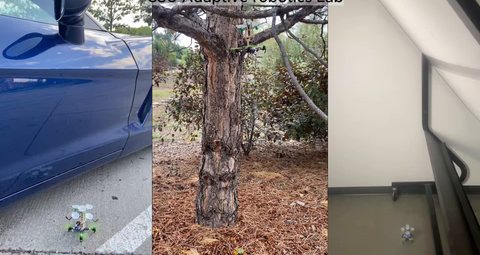 A Hybrid Perching Mechanism for Aerial Robots: Branch and Surface Perching with Large Surface Orientation MisalignmentIEEE Robotics and Automation Letters, 2026
- Adv. Robot. Res.
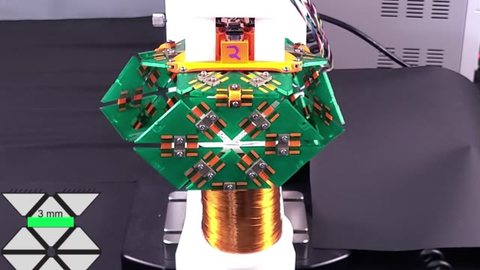 Stiffness-Programmable Origami Robots With Tendon-Driven Actuation via Multimaterial 3D PrintingAdvanced Robotics Research, 2026
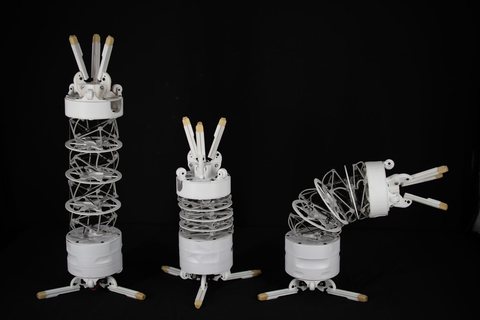
2025
- T-Mech
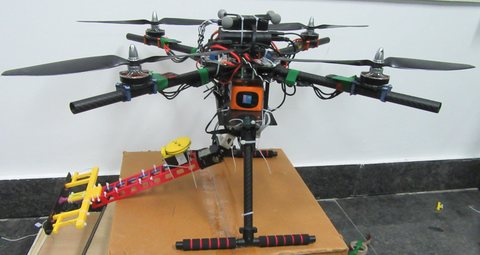 An Integrated Approach to Aerial Grasping: Combining a Bistable Gripper with Adaptive ControlIEEE/ASME Transactions on Mechatronics, 2025
- AIS
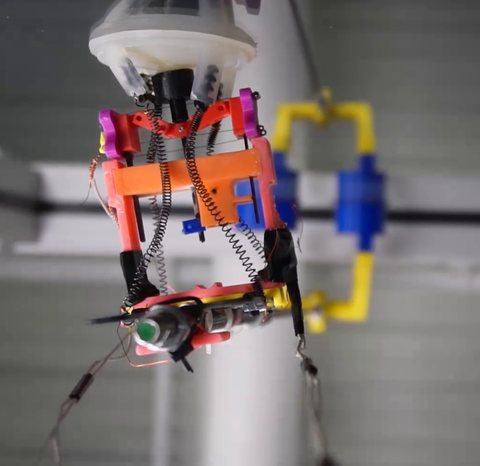 Tunable Mechanism Enables Robust Surface Perching under Different Landing Impacts and Orientation MisalignmentAdvanced Intelligent Systems, 2025
2024
- Phil. Trans. A
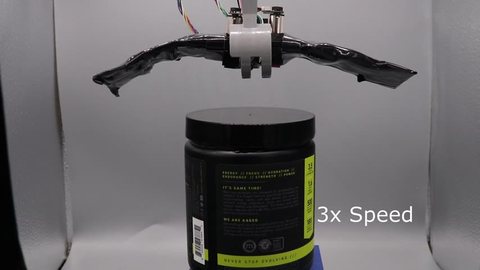 Reconfigurable Origami with Variable Stiffness Joints for Adaptive Robotic Locomotion and GraspingPhilosophical Transactions of the Royal Society A, 2024
- RoboSoft
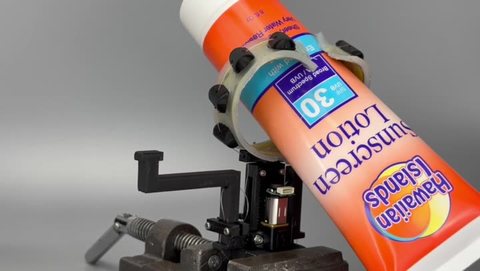 Bistable Spring Steel Grippers for Passive GraspingIn IEEE International Conference on Soft Robotics (RoboSoft), 2024
- T-Mech
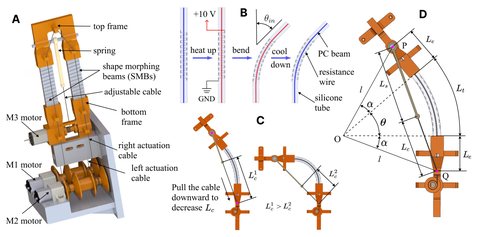 Tuning Modules with Elastic Instabilities On-the-Fly for Reconfigurable Shapes and MotionsIEEE/ASME Transactions on Mechatronics, 2024
2023
- Nat. Commun.
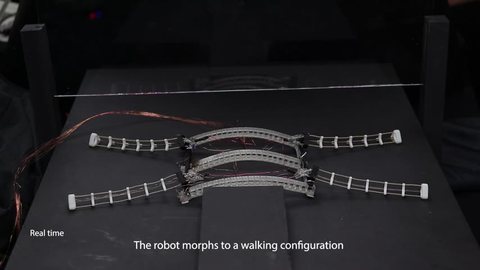
- T-Mech
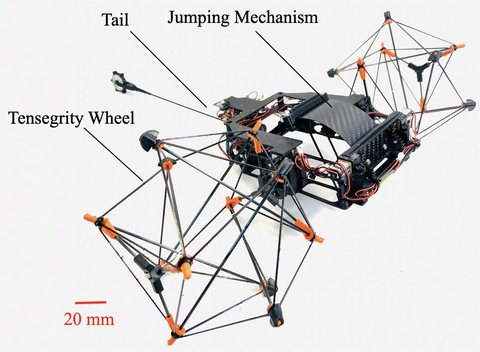 A Shape-Changing Wheeling and Jumping Robot Using Tensegrity Wheels and Bistable MechanismIEEE/ASME Transactions on Mechatronics, 2023
- ACC
 Controlling the Shape of Soft Robots Using the Koopman OperatorIn American Control Conference (ACC), 2023
2022
- Mater. Horiz.
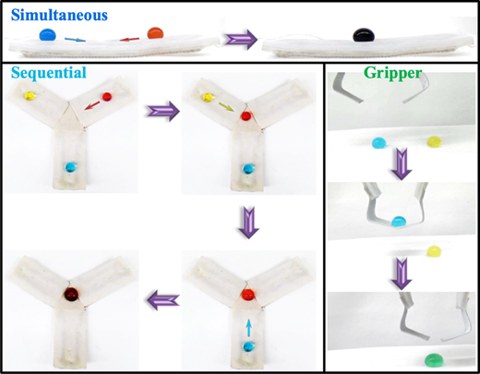
- T-Mech
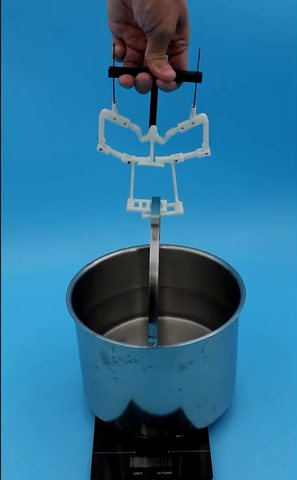 A Mechanically Intelligent and Passive Gripper for Aerial Perching and GraspingIEEE/ASME Transactions on Mechatronics, 2022
- T-Mech
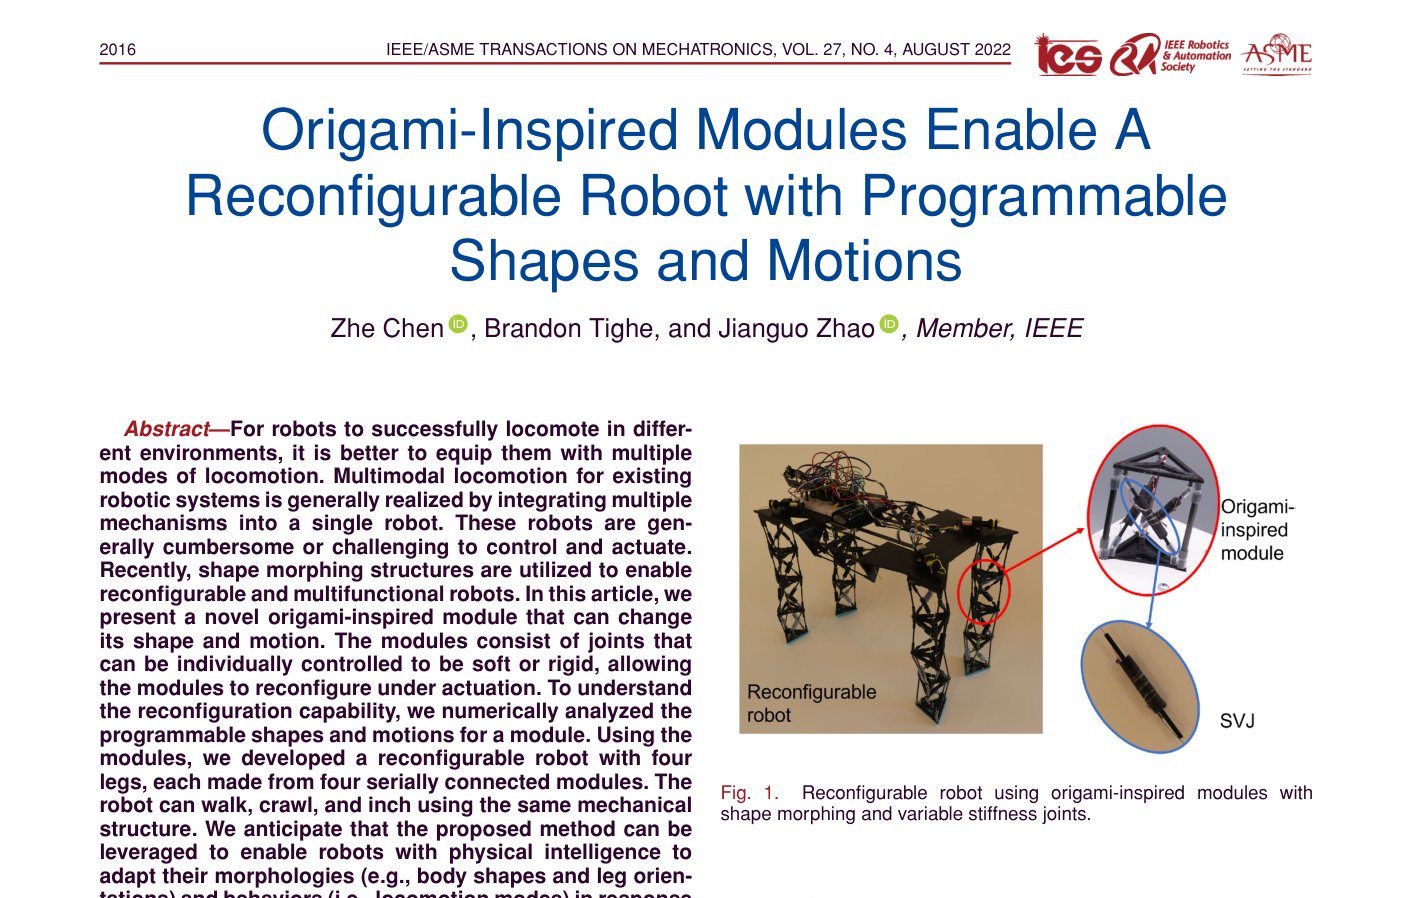
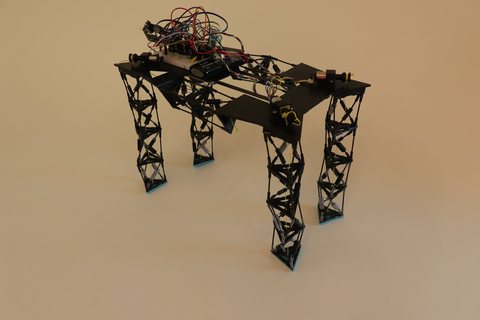 Origami-Inspired Modules Enable A Reconfigurable Robot with Programmable Shapes and MotionsIEEE/ASME Transactions on Mechatronics, 2022
- ICRA
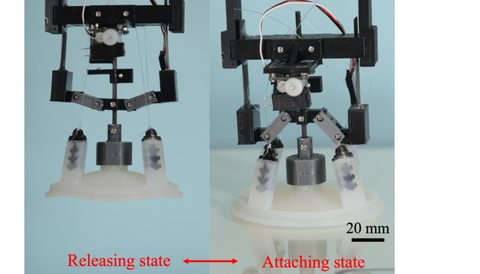 A Novel Passive Mechanism for Flying Robots to Perch onto SurfacesIn IEEE International Conference on Robotics and Automation (ICRA), 2022
- T-RO
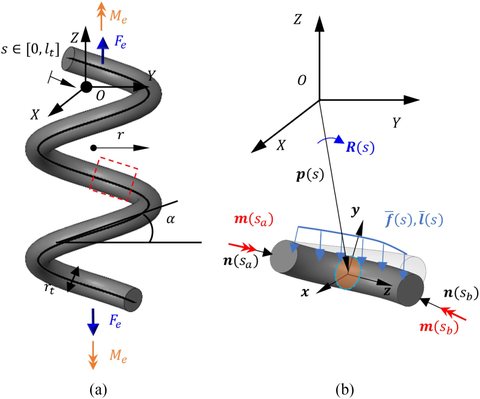 Physics-based Modeling of Twisted-and-Coiled Actuators Using Cosserat Rod TheoryIEEE Transactions on Robotics, 2022
2021
- T-MECH
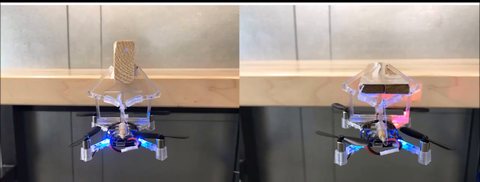 Compliant Bistable Grippers Enable Passive Perching for Micro Aerial VehiclesIEEE/ASME Transactions on Mechatronics, 2021
- Soft Robot.
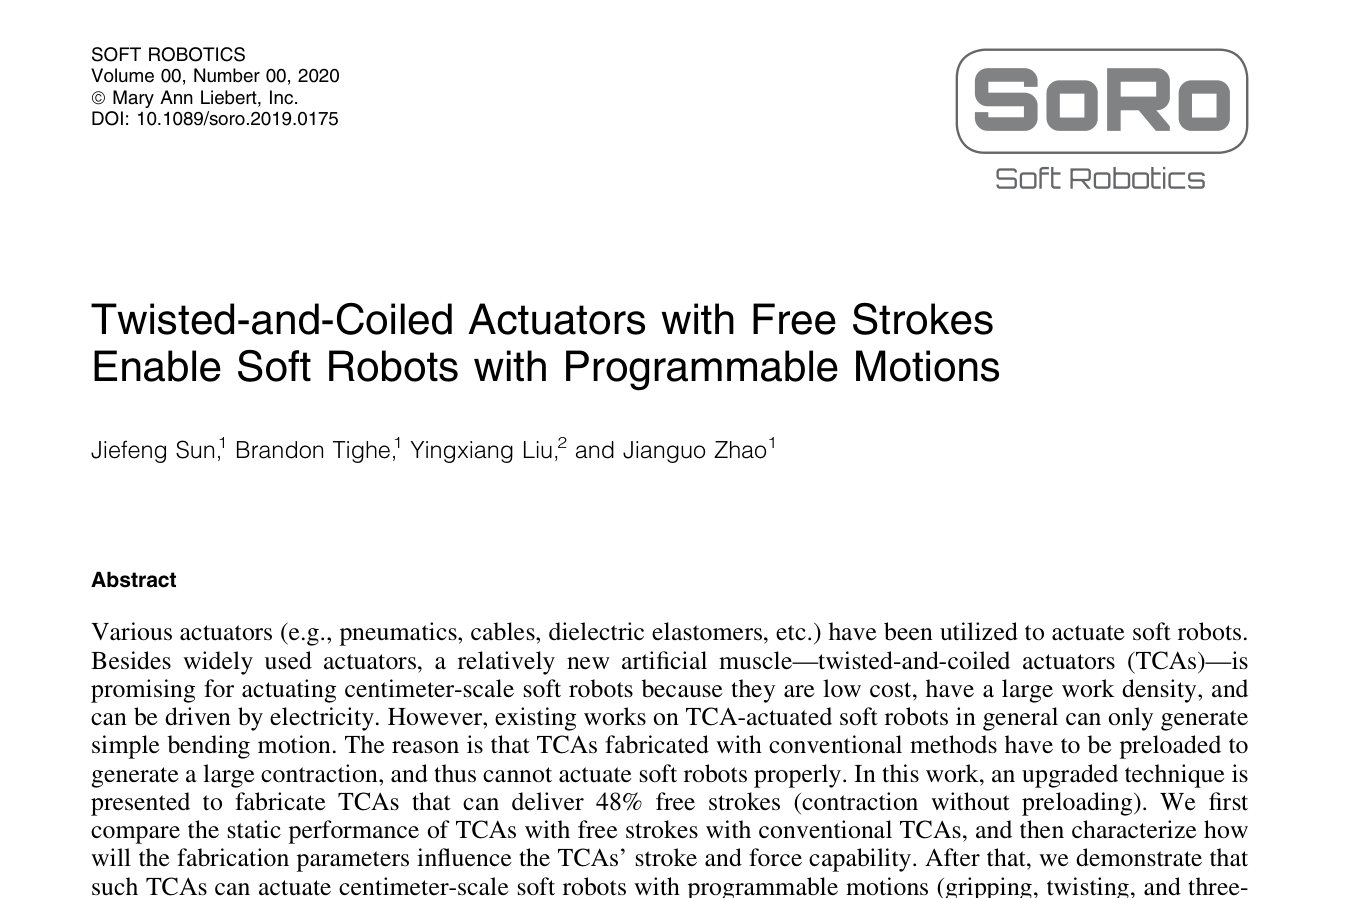
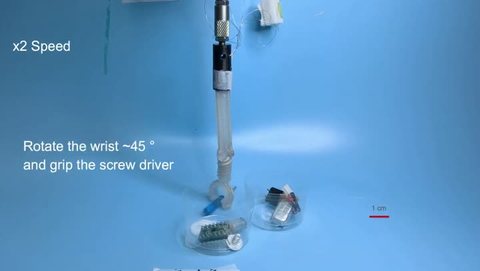 Twisted-and-Coiled Actuators with Free Strokes Enable Soft Robots with Programmable MotionsSoft Robotics, 2021
2020
- Sci. Adv.
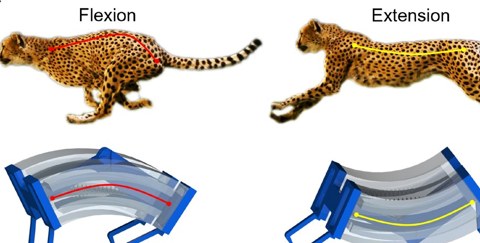 Leveraging Elastic Instabilities for Amplified Performance: Spine-Inspired High-Speed and High-Force Soft RobotsScience Advances, 2020
- ICRA
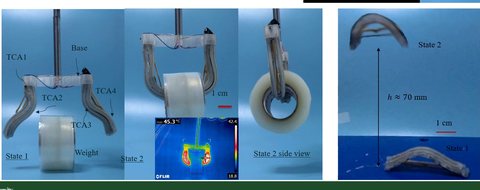 Tuning the Energy Landscape of Soft Robots for Fast and Strong MotionIn IEEE International Conference on Robotics and Automation (ICRA), 2020
2019
- T-MECH
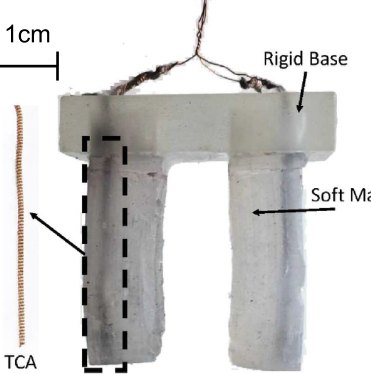 Modeling of Soft Robots Actuated by Twisted-and-Coiled ActuatorsIEEE/ASME Transactions on Mechatronics, 2019
- Sci. Adv.
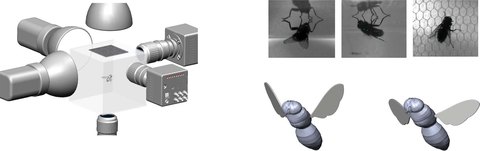 Flies Land Upside Down on a Ceiling Using Rapid Visually Mediated Rotational ManeuversScience Advances, 2019
- RA-L
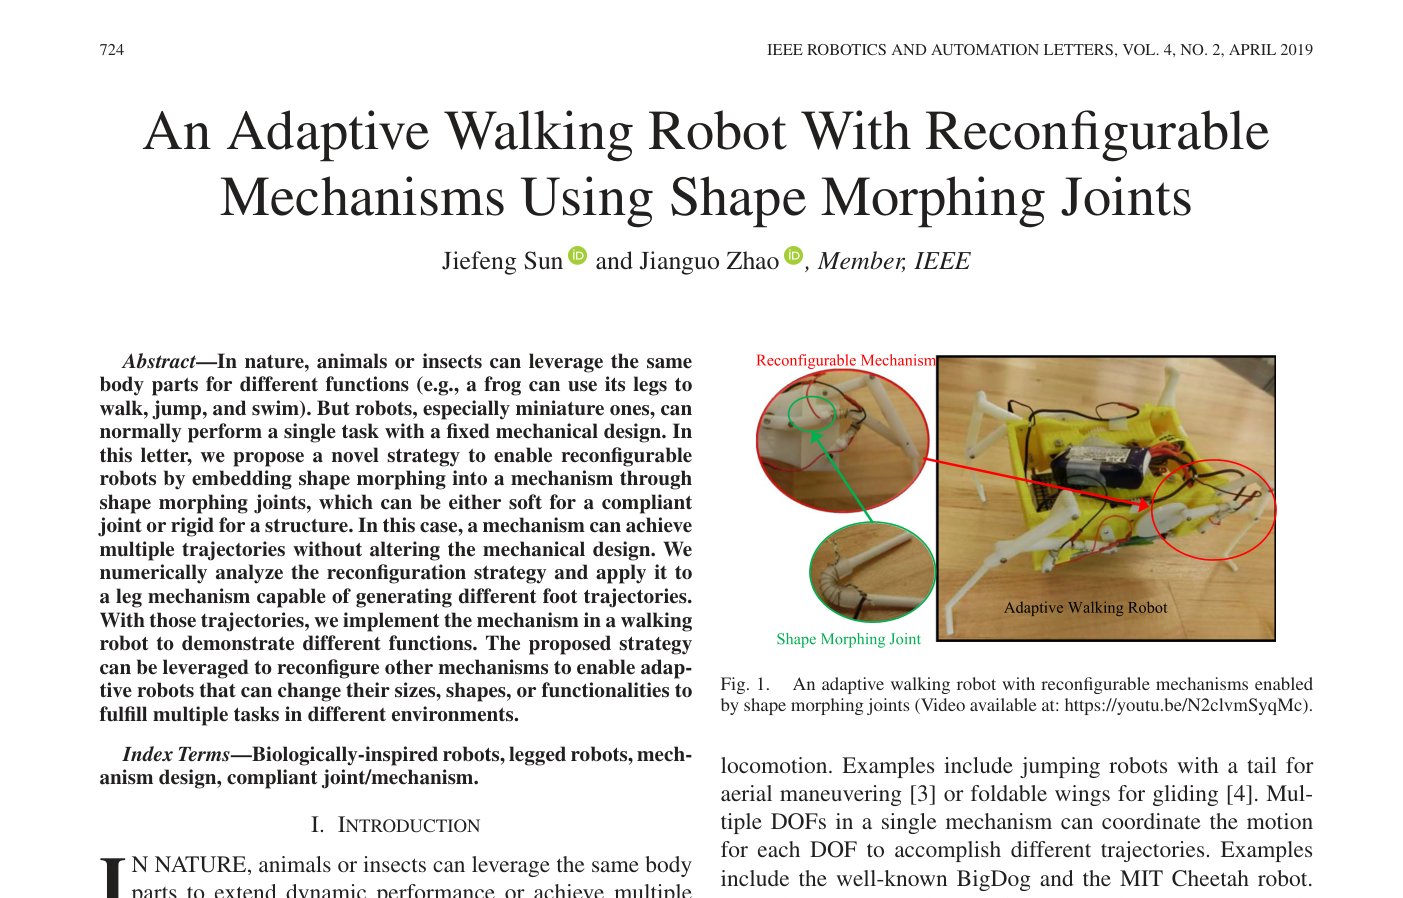
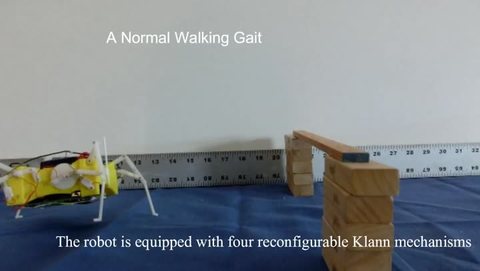 An Adaptive Walking Robot with Reconfigurable Mechanisms Using Shape Morphing JointsIEEE Robotics and Automation Letters, 2019
- B&B
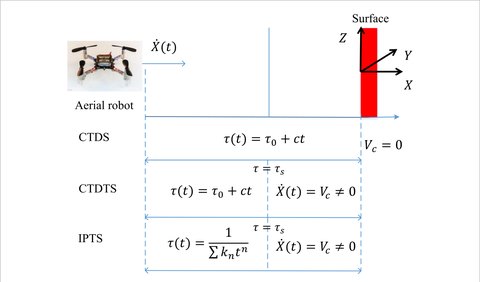 Optimal Trajectory Generation for Time-to-Contact Based Aerial Robotic PerchingBioinspiration & Biomimetics, 2019
- ICRA
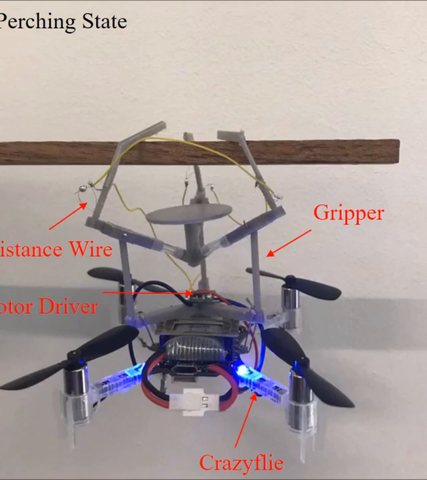 Compliant Bistable Gripper for Aerial Perching and GraspingIn IEEE International Conference on Robotics and Automation (ICRA), 2019
2018
- JMR
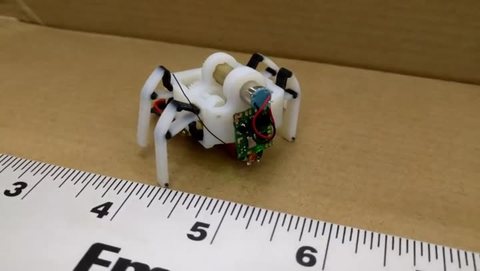 Development and Analysis of a Three-Dimensional Printed Miniature Walking Robot With Soft Joints and LinksASME Journal of Mechanisms and Robotics, 2018
- IROS
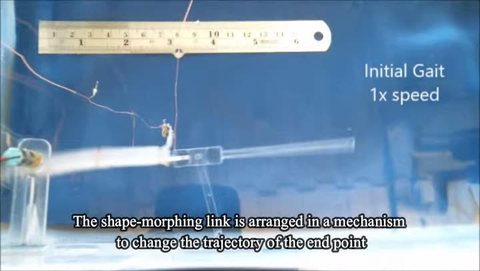 Embedded and Controllable Shape Morphing with Twisted-and-Coiled ActuatorsIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2018Finalist for the Best Student Paper Award
2017
- B&B
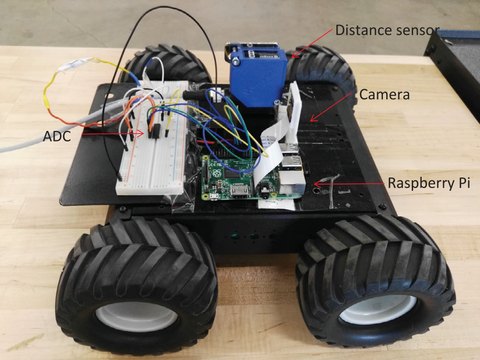 Bio-inspired Vision Based Robot Control Using Featureless Estimations of Time-to-ContactBioinspiration & Biomimetics, 2017
- ICRA
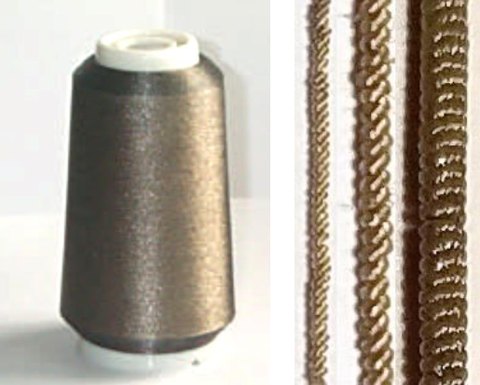 A Physics Based Model for Twisted and Coiled ActuatorIn IEEE International Conference on Robotics and Automation (ICRA), 2017
2015
- T-MECH
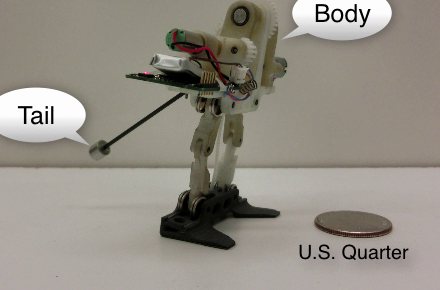 MSU Tailbot: Controlling Aerial Maneuver of a Miniature-Tailed Jumping RobotIEEE/ASME Transactions on Mechatronics, 2015
2014
- ICRA
 A Miniature 25 Grams Running and Jumping RobotIn IEEE International Conference on Robotics and Automation (ICRA), 2014
2013
- IROS
 Controlling Aerial Maneuvering of a Miniature Jumping Robot Using Its TailIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2013
- T-RO
 MSU Jumper: A Single-Motor-Actuated Miniature Steerable Jumping RobotIEEE Transactions on Robotics, 2013