Reconfigurable Robots
One body, many functions. Variable-stiffness joints, origami and tensegrity modules, and robots that link up into new shapes.
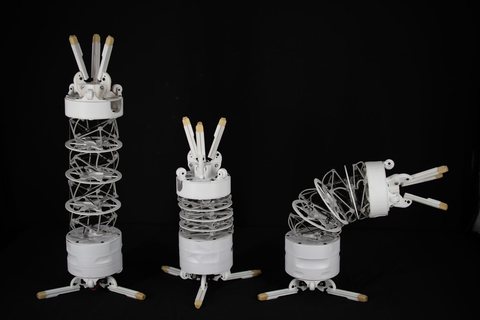
Most robots use each body part for one job, fixed by their mechanical design. Our reconfigurable robots can change how their parts are arranged or how stiff their joints are, so the same hardware can walk, crawl, grasp, or roll, and several robots can join into a larger one.
Questions we work on
- Programming motion with stiffness. If some joints are soft and others rigid, the same actuator produces different motions. How do we design joints whose stiffness can be set, and even changed while the robot runs?
- Modular structures. How can origami-inspired and tensegrity modules be stacked and combined into legs, fingers, and bodies with many possible shapes?
- Choosing the best configuration. Given a task, which stiffness or shape should the robot take? We use models and learning to choose the configuration and the controller together.
- Robots that join together. How can individual robots dock with one another to form chains, loops, and branches that do what one robot cannot?
Key results
Shape-morphing joints. A walking robot reconfigures its legs to step over an obstacle.
Origami-inspired modules. The same four legs can walk, crawl, inch, or grasp.
Stiffness-programmable origami. Heating one insert switches the robot's gait so it fits under a gap.
Modular tensegrity robots. TeCoBots link up to manipulate objects together.
Related robots
- TeCoBot: soft tensegrity robots that link into new shapes.
- Stiffness-Programmable Origami Robot: a three-fingered origami robot that grasps and walks.
- Origami-Inspired Reconfigurable Robot: a four-legged robot built from origami modules.
Publications
- T-Mech
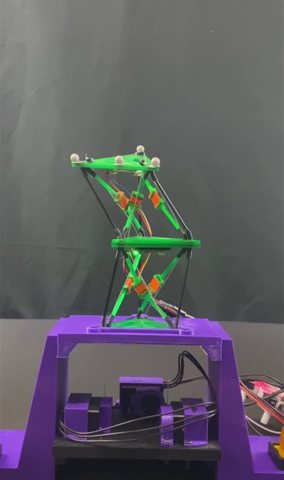 Co-Optimizing Physical Reconfiguration Parameters and Controllers for a Reconfigurable ManipulatorIEEE/ASME Transactions on Mechatronics, 2026
- Adv. Robot. Res.
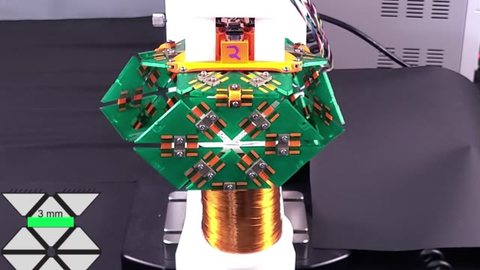 Stiffness-Programmable Origami Robots With Tendon-Driven Actuation via Multimaterial 3D PrintingAdvanced Robotics Research, 2026
- Phil. Trans. A
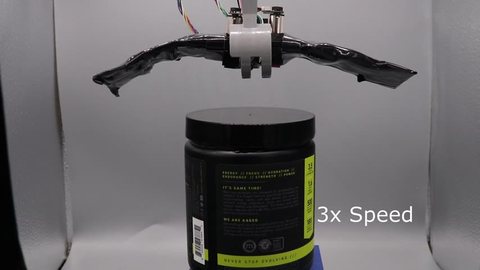 Reconfigurable Origami with Variable Stiffness Joints for Adaptive Robotic Locomotion and GraspingPhilosophical Transactions of the Royal Society A, 2024
- T-Mech
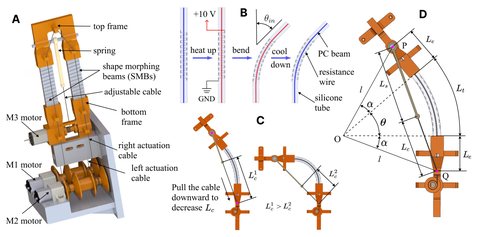 Tuning Modules with Elastic Instabilities On-the-Fly for Reconfigurable Shapes and MotionsIEEE/ASME Transactions on Mechatronics, 2024
- T-Mech
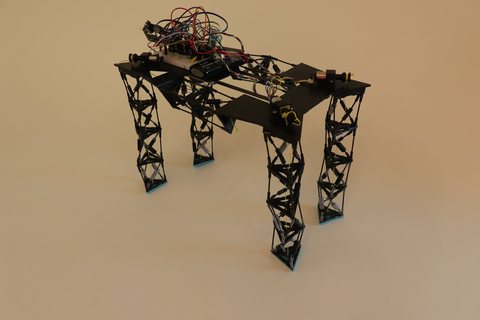 Origami-Inspired Modules Enable A Reconfigurable Robot with Programmable Shapes and MotionsIEEE/ASME Transactions on Mechatronics, 2022
- RA-L
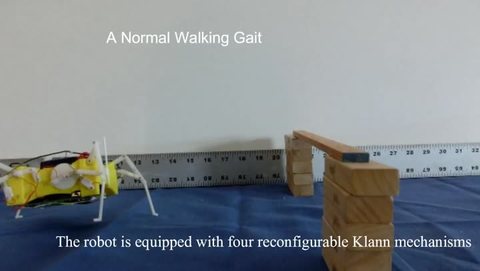 An Adaptive Walking Robot with Reconfigurable Mechanisms Using Shape Morphing JointsIEEE Robotics and Automation Letters, 2019