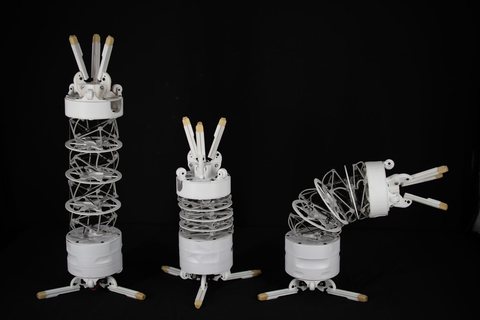
Multimodal Robots
Small robots that move in more than one way, rolling, jumping, walking, climbing, and swimming, to cross terrain no single mode can handle.
Animals switch between walking, running, jumping, climbing, and swimming as the terrain changes. Most robots can do only one of these. We build small robots that combine several ways of moving, so they can cross rubble, steps, gaps, sand, snow, and water, which matters for search and rescue, inspection, and exploration.
Questions we work on
- Combining modes in a small body. How can a lightweight robot wheel and jump, or walk and climb, without carrying a separate mechanism for each mode?
- Robust bodies. Can compliant structures such as tensegrity wheels and soft joints absorb impacts and help a small robot survive falls?
- Control in the air. How can a jumping robot use a tail to control its body angle in mid-air and land safely?
Key results
Tensegrity wheels and a bistable jumper. The robot crosses an obstacle course of rocks, a wall, a pipe, a gap, a step, and a slope (2× speed).
MSU Tailbot. A 26-gram robot that runs, jumps up steps, and uses its tail to steer in the air.
MiniWalker. A multi-material 3D-printed walking robot with soft joints and links.
TeCoBot. One soft robot that inches, crawls, rolls, turns, and climbs inside a pipe.
Related robots
- Tensegrity-Wheeled Jumping Robot: rolls, changes shape, and jumps over obstacles.
- TeCoBot: soft tensegrity robots with six ways to move on their own and more as a team.
Publications
- T-Mech
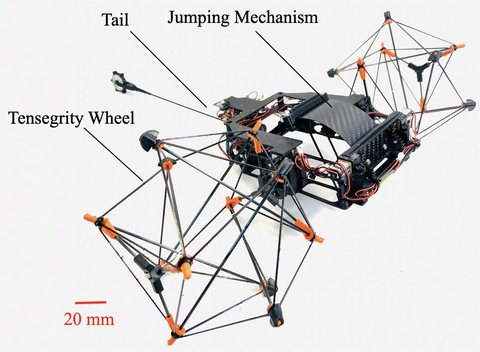 A Shape-Changing Wheeling and Jumping Robot Using Tensegrity Wheels and Bistable MechanismIEEE/ASME Transactions on Mechatronics, 2023
- JMR
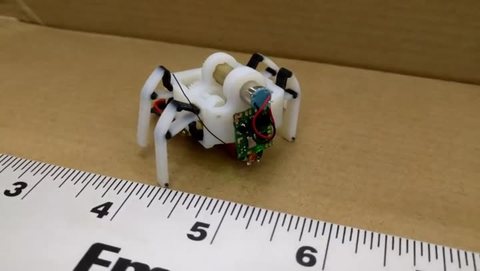 Development and Analysis of a Three-Dimensional Printed Miniature Walking Robot With Soft Joints and LinksASME Journal of Mechanisms and Robotics, 2018
- T-MECH
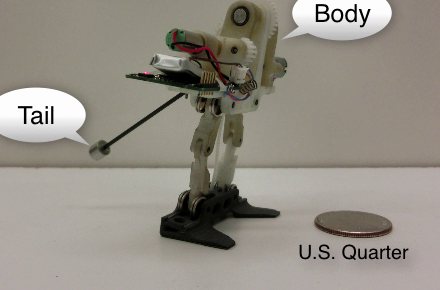 MSU Tailbot: Controlling Aerial Maneuver of a Miniature-Tailed Jumping RobotIEEE/ASME Transactions on Mechatronics, 2015
- ICRA
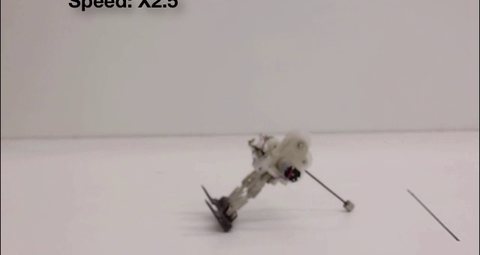 A Miniature 25 Grams Running and Jumping RobotIn IEEE International Conference on Robotics and Automation (ICRA), 2014
- IROS
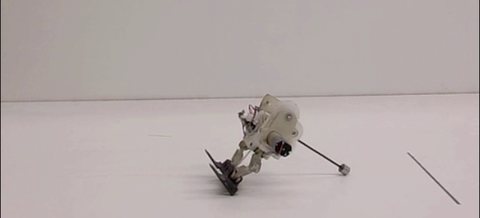 Controlling Aerial Maneuvering of a Miniature Jumping Robot Using Its TailIn IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2013
- T-RO
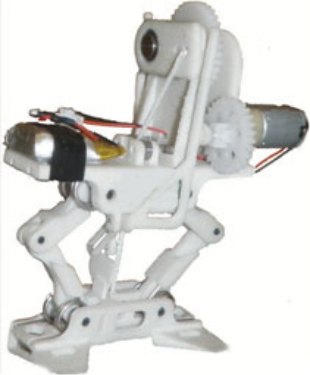 MSU Jumper: A Single-Motor-Actuated Miniature Steerable Jumping RobotIEEE Transactions on Robotics, 2013